RealMan ECO65-6F | 6DOF | 5kg (version force 6 axes)
Cobot polyvalent pour l'automatisation industrielle de précision
Le RealMan ECO65-6F est un robot collaboratif 6 axes à contrôle de force, d'une charge utile de 5 kg et d'une portée de 638,5 mm. Doté d'un capteur de force-couple 6 axes et d'une conception compacte (seulement 7,9 kg, contrôleur inclus), il est idéal pour les tâches précises à contrôle de force dans l'automatisation industrielle. Équipé d'un module de sécurité intégré et d'une fonction d'évitement des collisions.
Il prend en charge les protocoles industriels courants et une programmation flexible via plusieurs plateformes. Le pilotage s'effectue via une interface utilisateur intuitive, avec une architecture de commande efficace garantissant un fonctionnement stable et précis.
Les applications typiques incluent l'assemblage de précision, le contrôle de force, le collage et le pick-and-place automatisé. L'ECO65-6F est parfait pour les intégrateurs et les fabricants des secteurs de l'électronique, de l'automobile et de la fabrication haut de gamme qui recherchent un bras robotisé précis et flexible.
Produits phares
(1) With an integrated design of the control cabinet and the arm itself, it weighs only 7.9 kg while delivering an effective payload of 5 kg and a peak load capacity of up to 9 kg, achieving an impressive load-to-self-weight ratio of 1:1.56. Its optimized structure not only ensures ultra-lightweight portability but also offers a flexible working range—with an effective working radius of 638.5 mm and an ultra-long arm span of up to 900 mm, coupled with a safe and streamlined shape design, it can easily meet the needs of wide-range operations in various scenarios.
(2) The open API function library further enhances its flexibility, supporting C/C++/C#/Python programming languages as well as Windows/Linux/ROS robot operating systems and various communication protocols. Moreover, it provides multiple forms of secondary development support, allowing users to customize and develop application solutions tailored to specific scenarios, greatly lowering the threshold for scenario-based deployment.
(3)The robotic arm excels in rich functionality and user-friendly interactivity, making it suitable for both professional and daily application scenarios such as physical therapy. In physical therapy, it can perform functions including fascia layer relaxation, pain relief, blood circulation promotion, functional recovery assistance, and beauty and skincare. It is equipped with various types of sensors, enabling independent or cooperative control of each unit for precise operation.
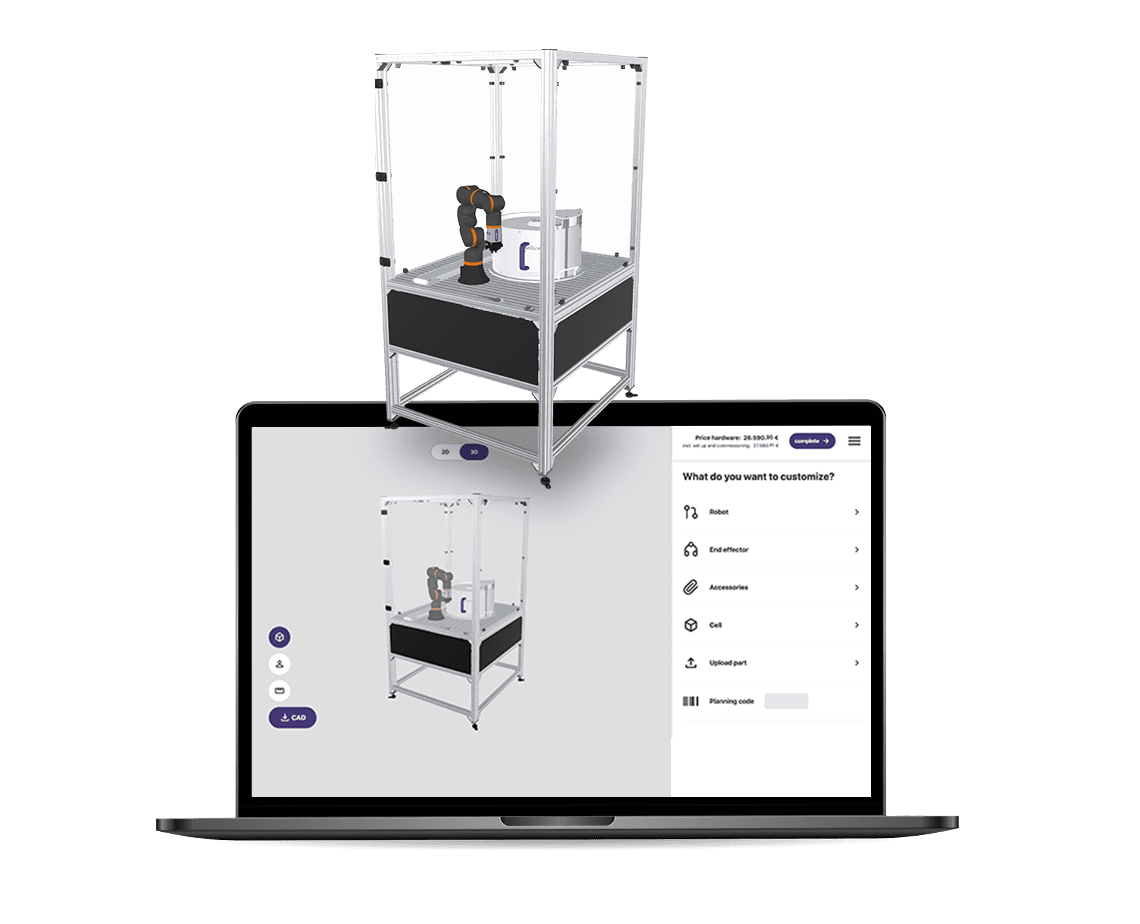
Solutions low cost créées avec RBTX
Téléchargements
Réservez un appel vidéo gratuit avec nos spécialistes