ReBeL Cobot incl. settimo asse | 7 DOF | 1500mm | 2kg
Varianti: 1000 mm
ReBeL Cobot con settimo asse per un'automazione estesa
Questa soluzione all-in-one combina il ReBeL Cobot (4, 5 o 6 DOF) con un settimo asse, un asse lineare a cinghia drylin® ZLW-20200 con corsa fino a 3.000 mm. Il sistema consente un raggio d'azione fino a 5.800 mm (in base alla configurazione), un carico utile di 2 kg e una ripetibilità di ±1 mm.
Il controllo avviene tramite igus® Robot Control con integrazione diretta sul bus CAN. Il settimo asse può essere sincronizzato con il robot come asse esterno. Protocolli supportati: Modbus TCP/IP, ROS, CANopen, I/O digitali. Il software è disponibile gratuitamente.
Applicazioni tipiche: pick & place, controllo qualità, servizio macchina, movimentazione di componenti di grandi dimensioni o di più stazioni. Ideale per PMI, produzione, logistica e automazione di laboratorio.
Highlights
The 7th axis bundle for the igus ReBeL!
Expand the workspace of your ReBeL in no time. With our individually and flexibly usable 7th axis, you can increase the operating radius of your ReBeL up to 5800mm! (according to technical design) Whether overhead or horizontal, both are possible thanks to our drylin® toothed belt axis ZLW-20200, with a long service life and no maintenance. Thanks to our tribologically optimized plastics, no additional lubrication is necessary.
Control
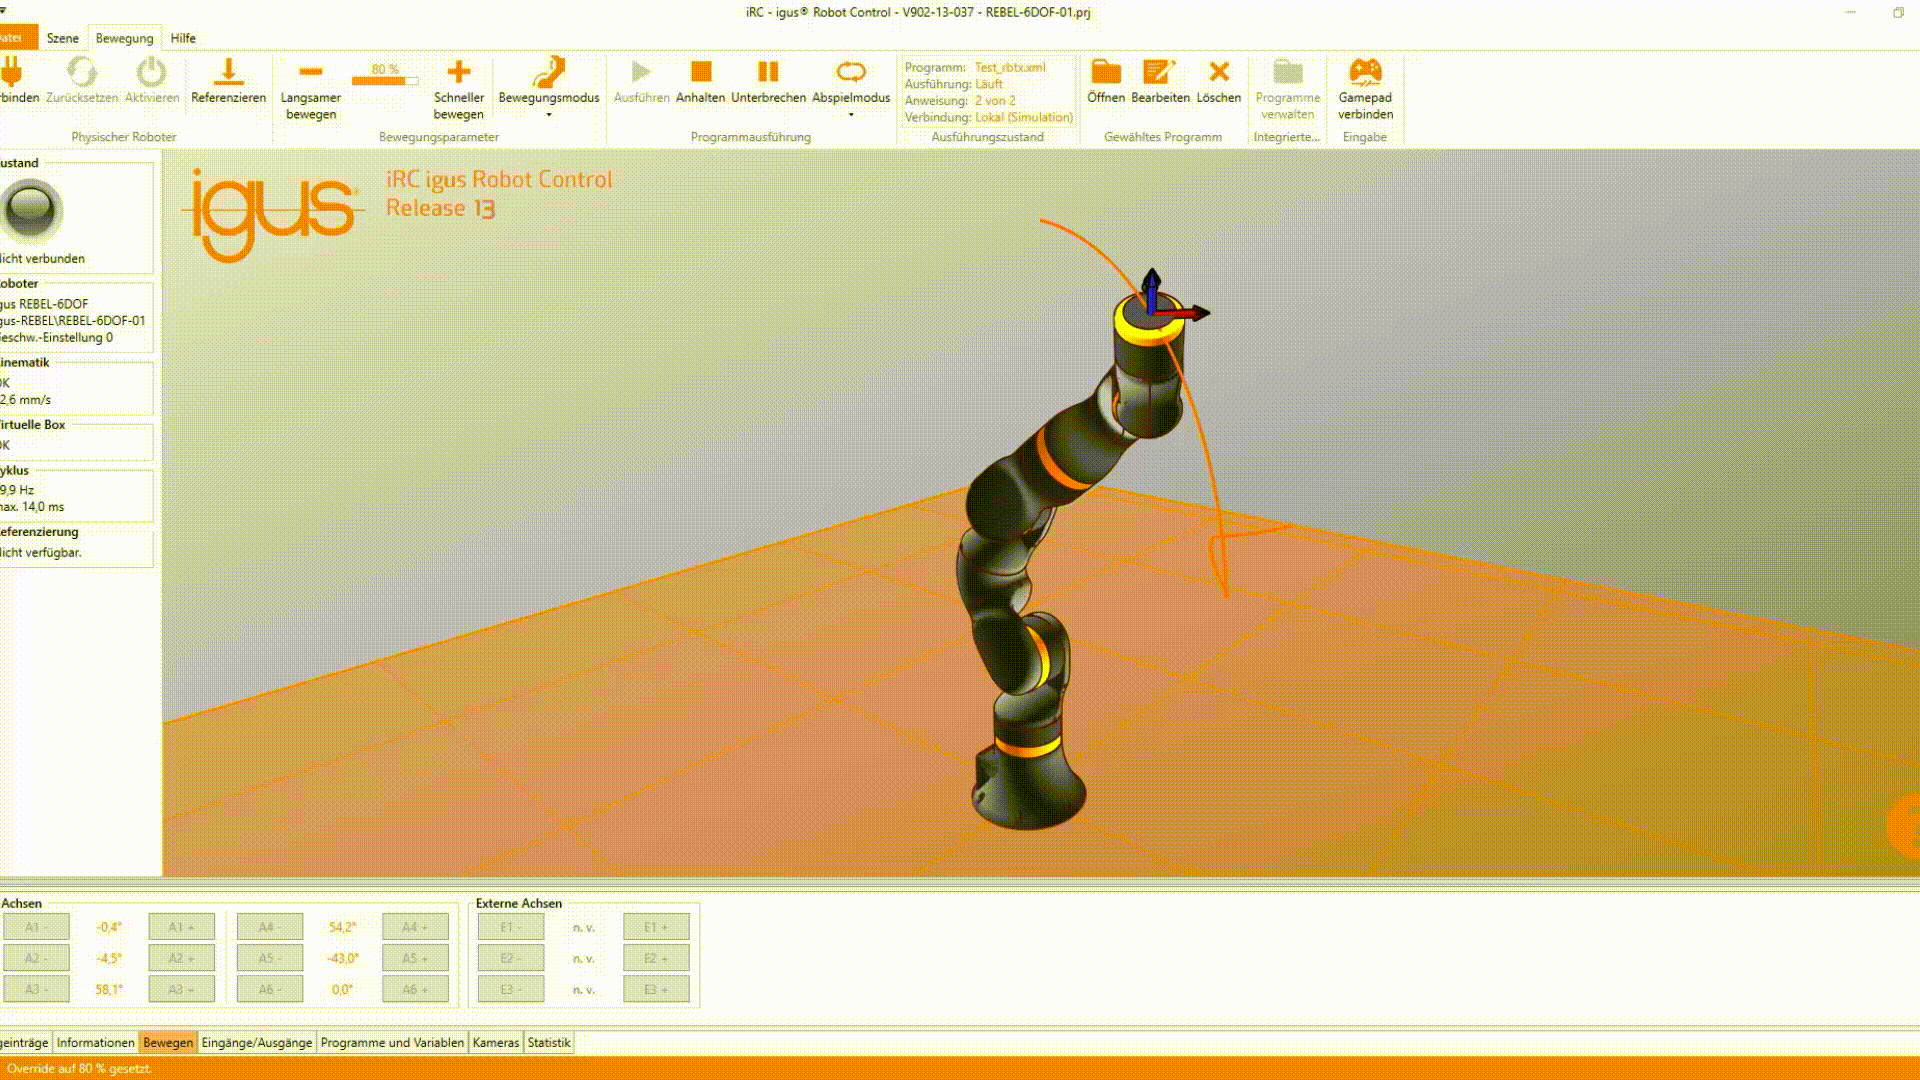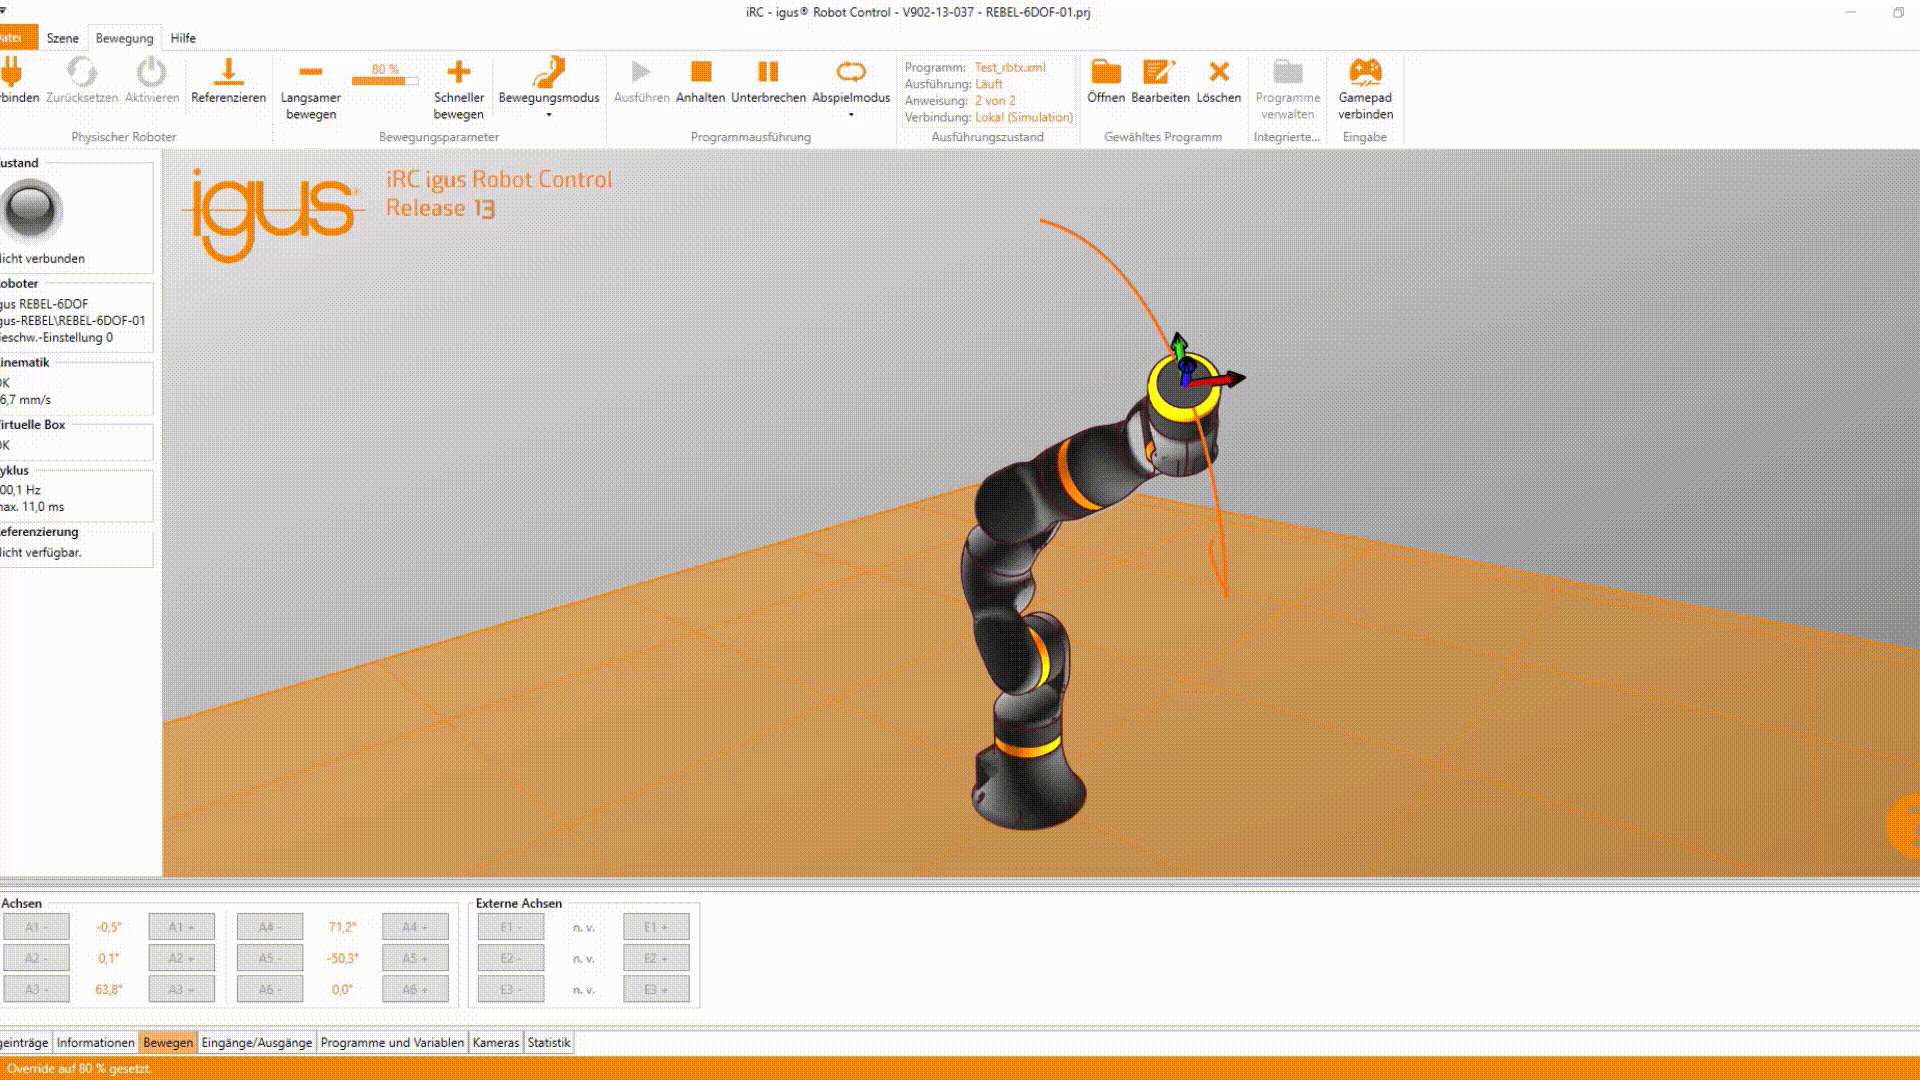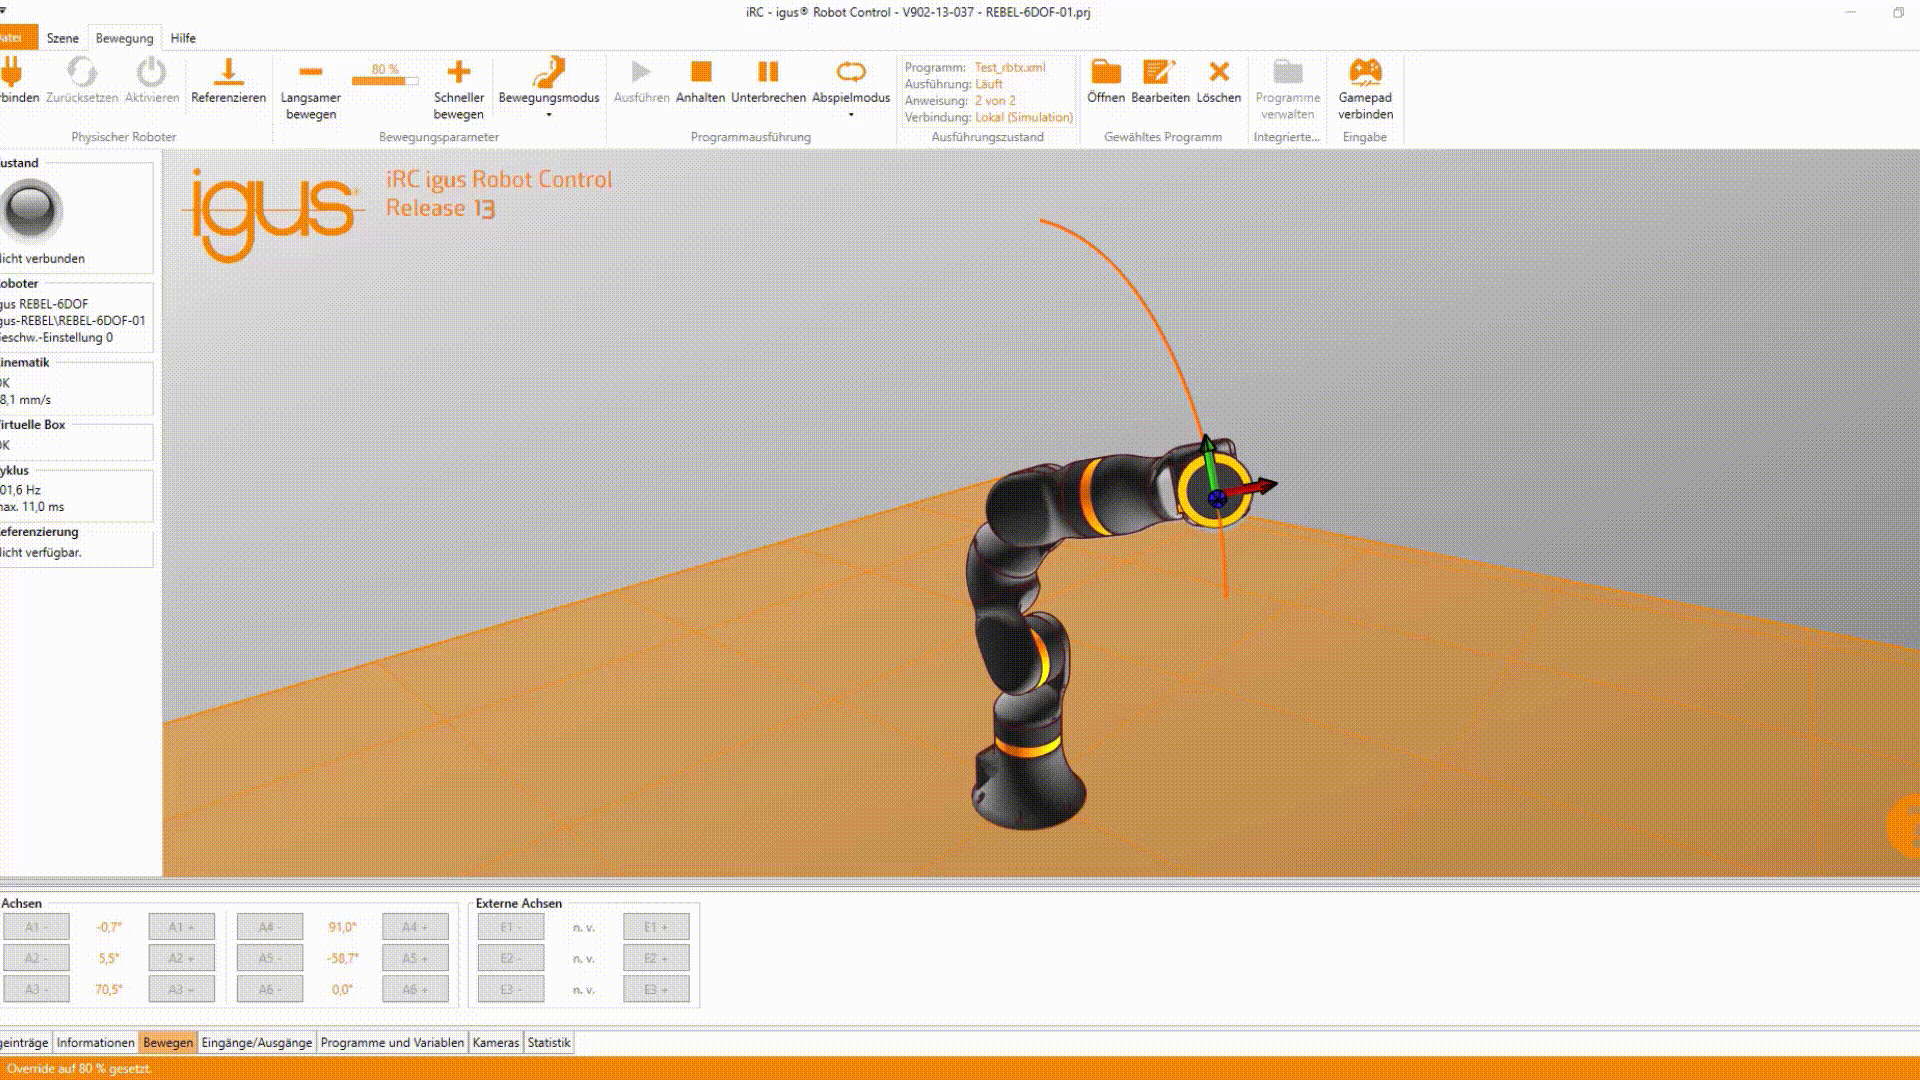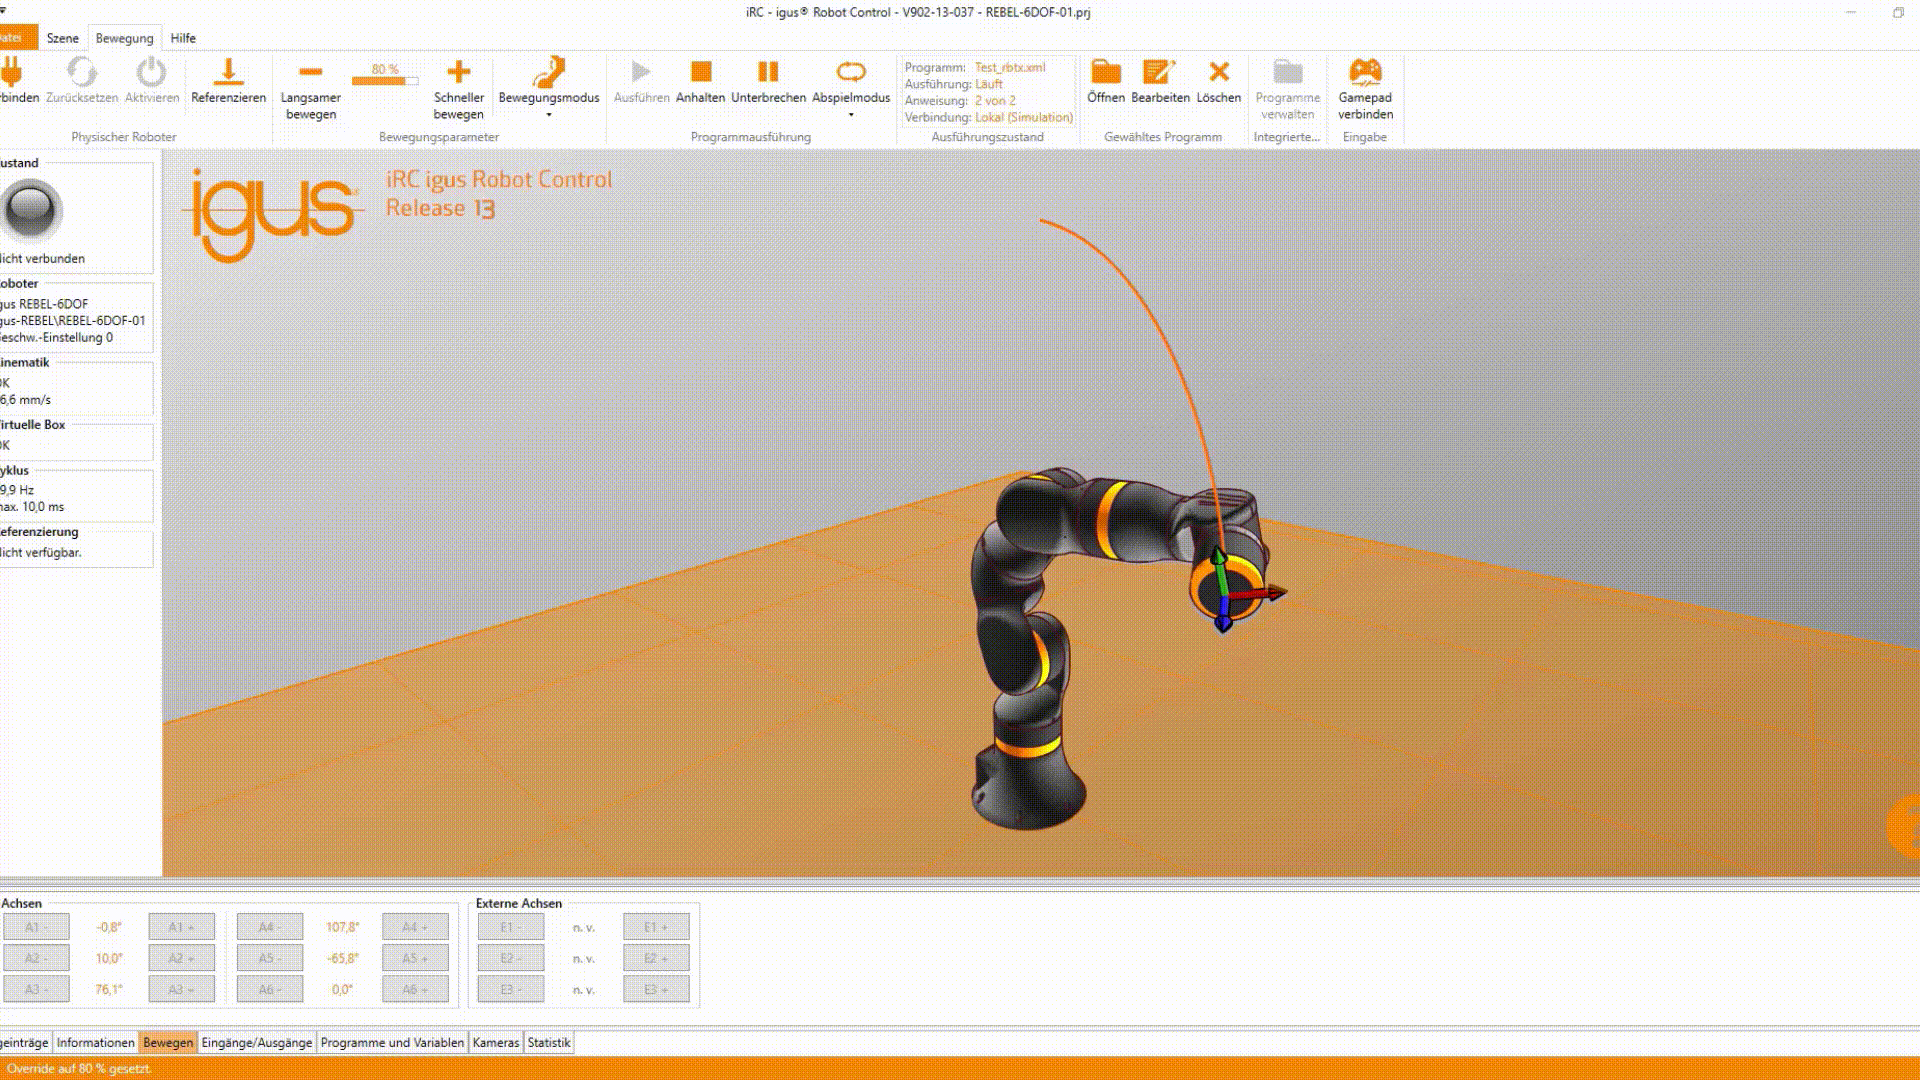
The new control box makes it possible to control the 7th axis directly via the igus Robot Control as an external axis. Thanks to the direct connection to the CAN bus, you receive a ready-to-connect solution with which you can move the 7th axis within a very short time. Simultaneous movement of the 7th axis and the robot in unlimited positions is also possible thanks to direct control via the igus Robot Control. You can download the software for free here: igus® Robot Control software.

Application areas
Typical applications of our 7th axes for the ReBeL are:
Pick & Place applications
Quality controls or barcode checks on large components
Processing multiple workstations
Process larger components that are outside the normal robot workspace
Soluzioni low cost realizzate con RBTX®
Prenota una videochiamata gratuita con un nostro esperto