Unitree G1 - Comp | Robot umanoide | Versione da competizione
Varianti: Football
Robot umanoide di livello agonistico per RoboCup, con locomozione ad alta velocità e stabilità ai massimi livelli
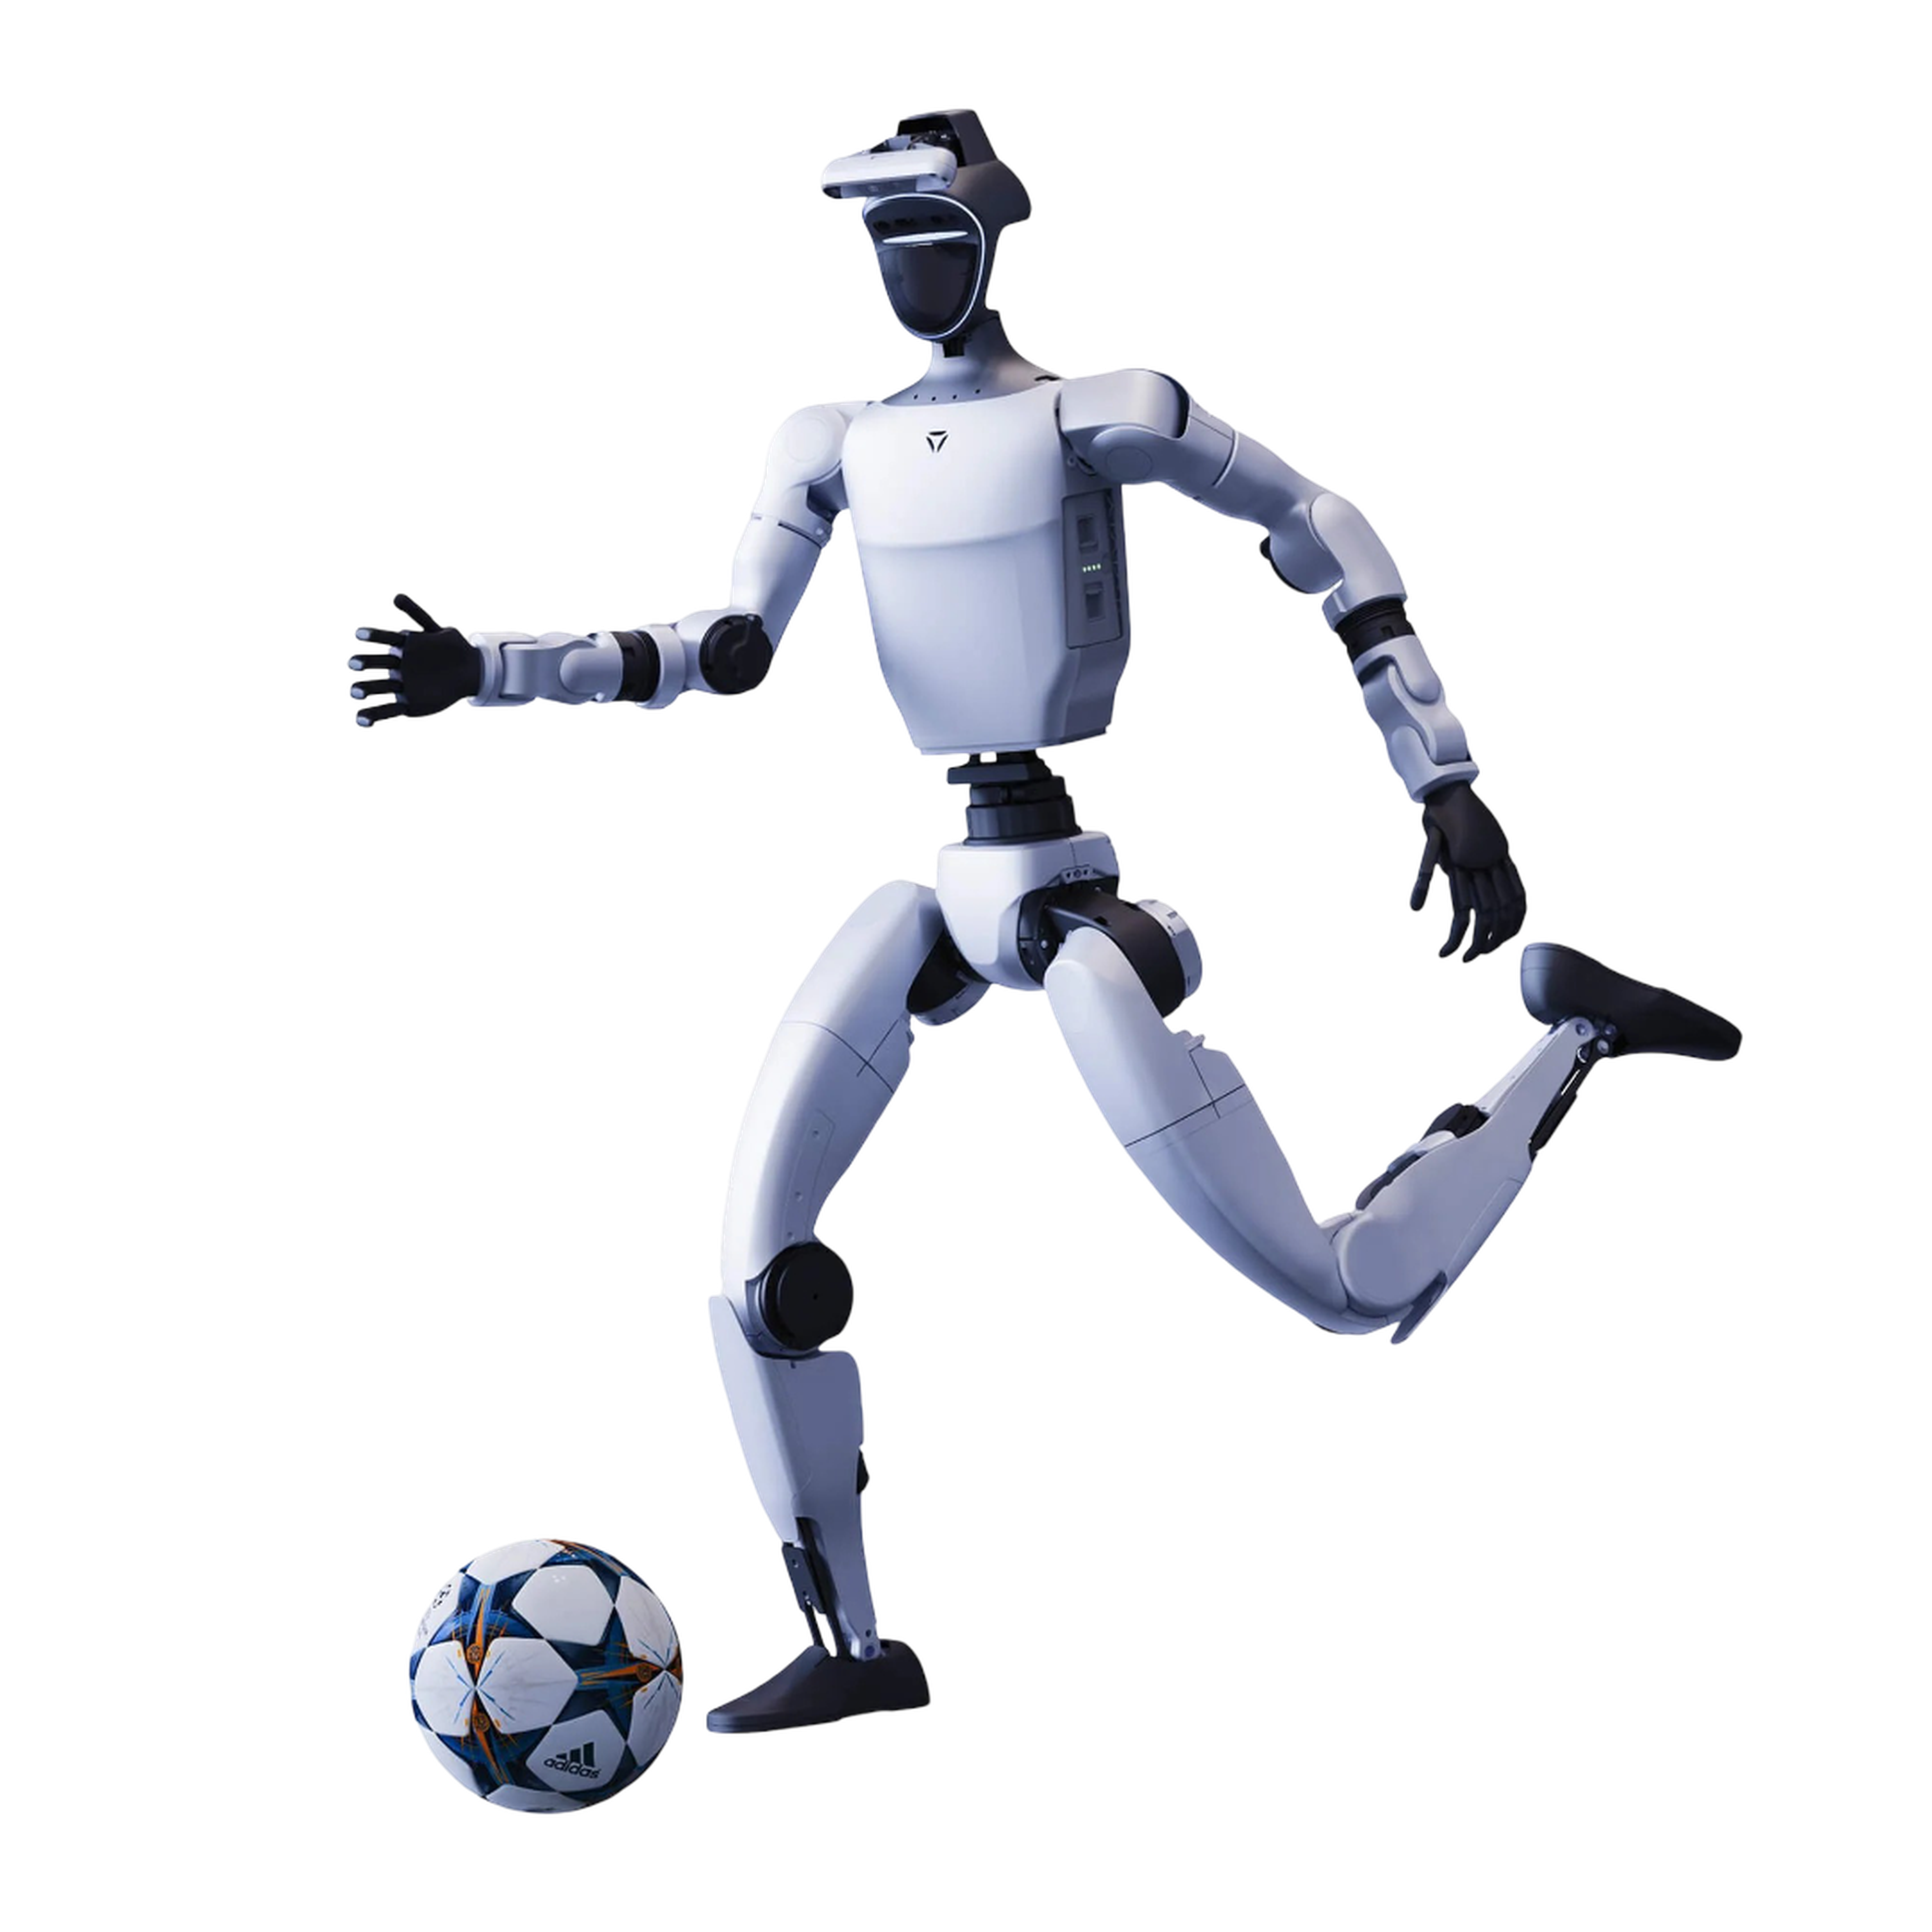
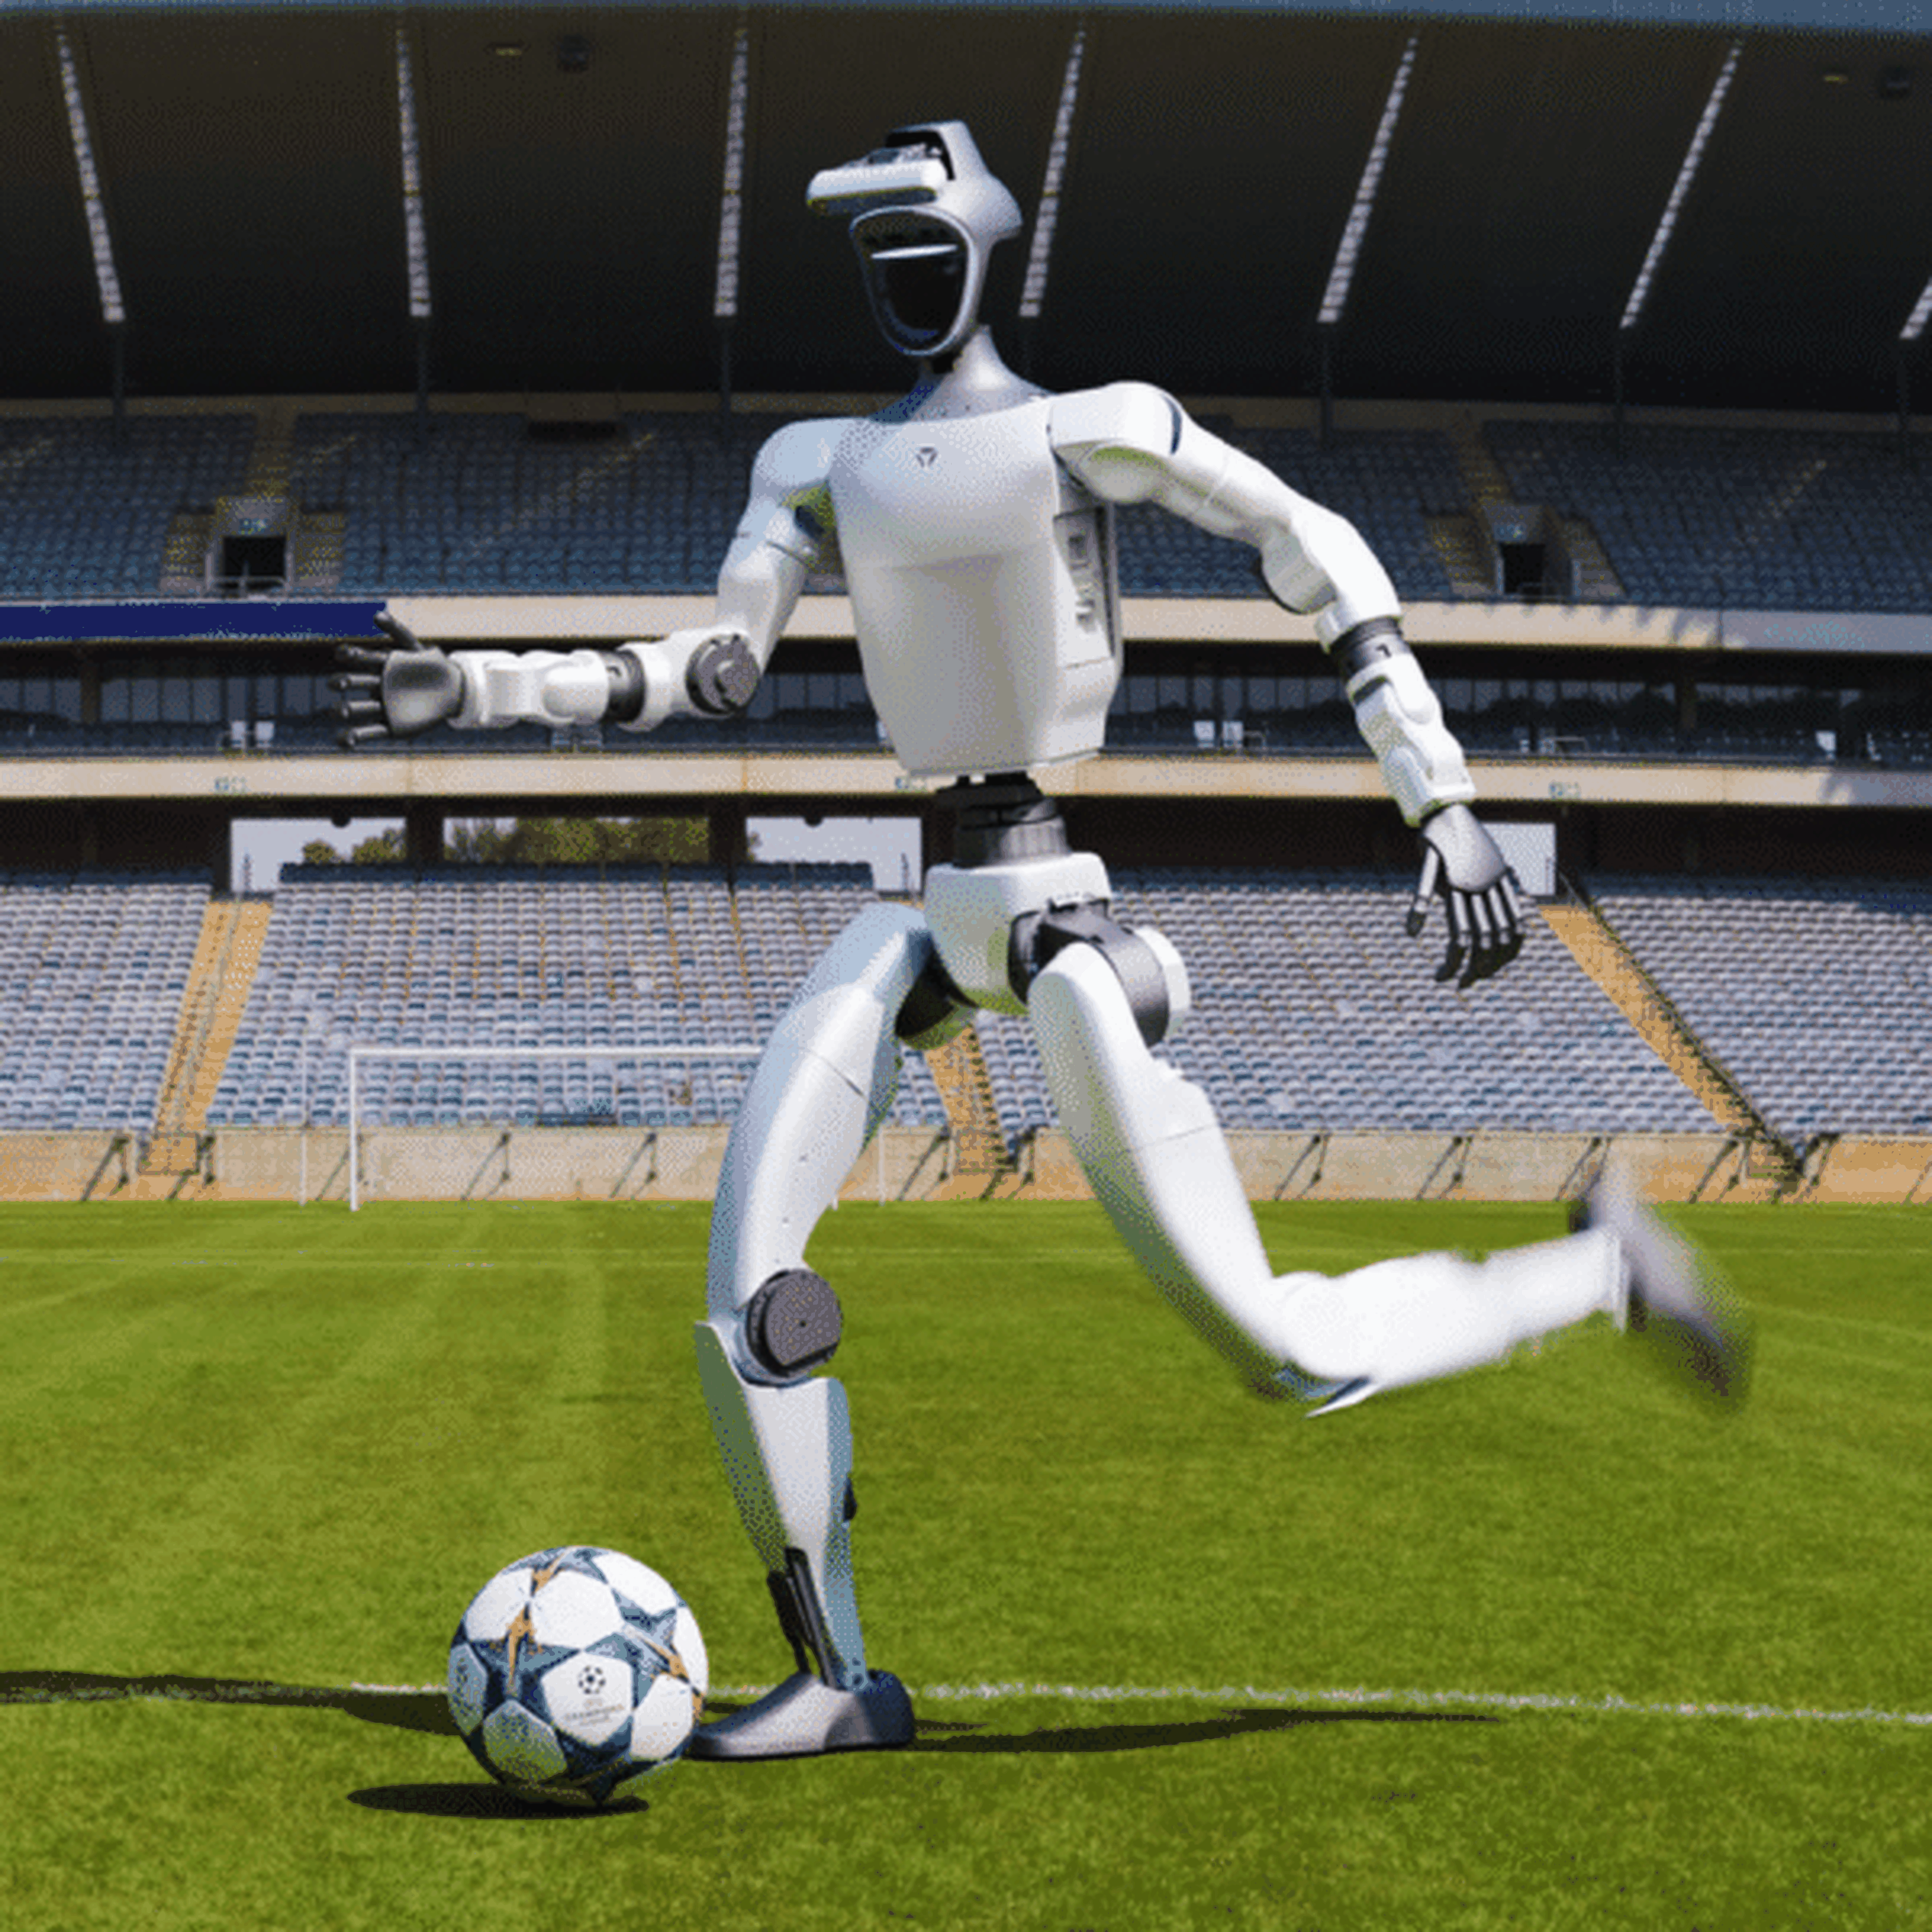
Il G1-Comp è un robot umanoide da 35 kg con 25–45 DOF e 120 Nm di coppia al ginocchio, che consentono rapida accelerazione, rotazioni stabili e recupero dopo gli urti. Il telaio pieghevole, da 1.320×450×200 mm a 690×450×300 mm, facilita il trasporto e l'agilità sul campo. Raggiunge una velocità di sprint di 3,3 m/s e mantiene una stabilità di beccheggio e rollio di ±2° su terreno erboso irregolare. Il LiDAR LIVOX MID-360, la visione di profondità RealSense e il rilevamento degli stadi YOLO11 consentono mappatura, inseguimento dei target e localizzazione degli avversari.
Il suo ecosistema software comprende un modulo Jetson Orin NX con 100–157 TOPS di potenza di calcolo AI, il framework RL unitree_rl_gym, le pipeline di simulazione Isaac Gym e Mujoco e un SDK dedicato per RoboCup che fornisce API per il controllo del movimento, il posizionamento spaziale, l'elaborazione visiva e l'integrazione con le regole di gara. I giunti a doppio encoder aumentano la precisione, mentre le batterie a sostituzione rapida garantiscono circa 2 ore di funzionamento continuo con supporto alla ricarica rapida.
Ideale per team che partecipano a RoboCup, gruppi di ricerca sulla locomozione, laboratori di reinforcement learning e sviluppatori che necessitano di autonomia umanoide ad alta velocità in ambienti dinamici multi-agente.
Highlights
25 DOF für Competition Robotics
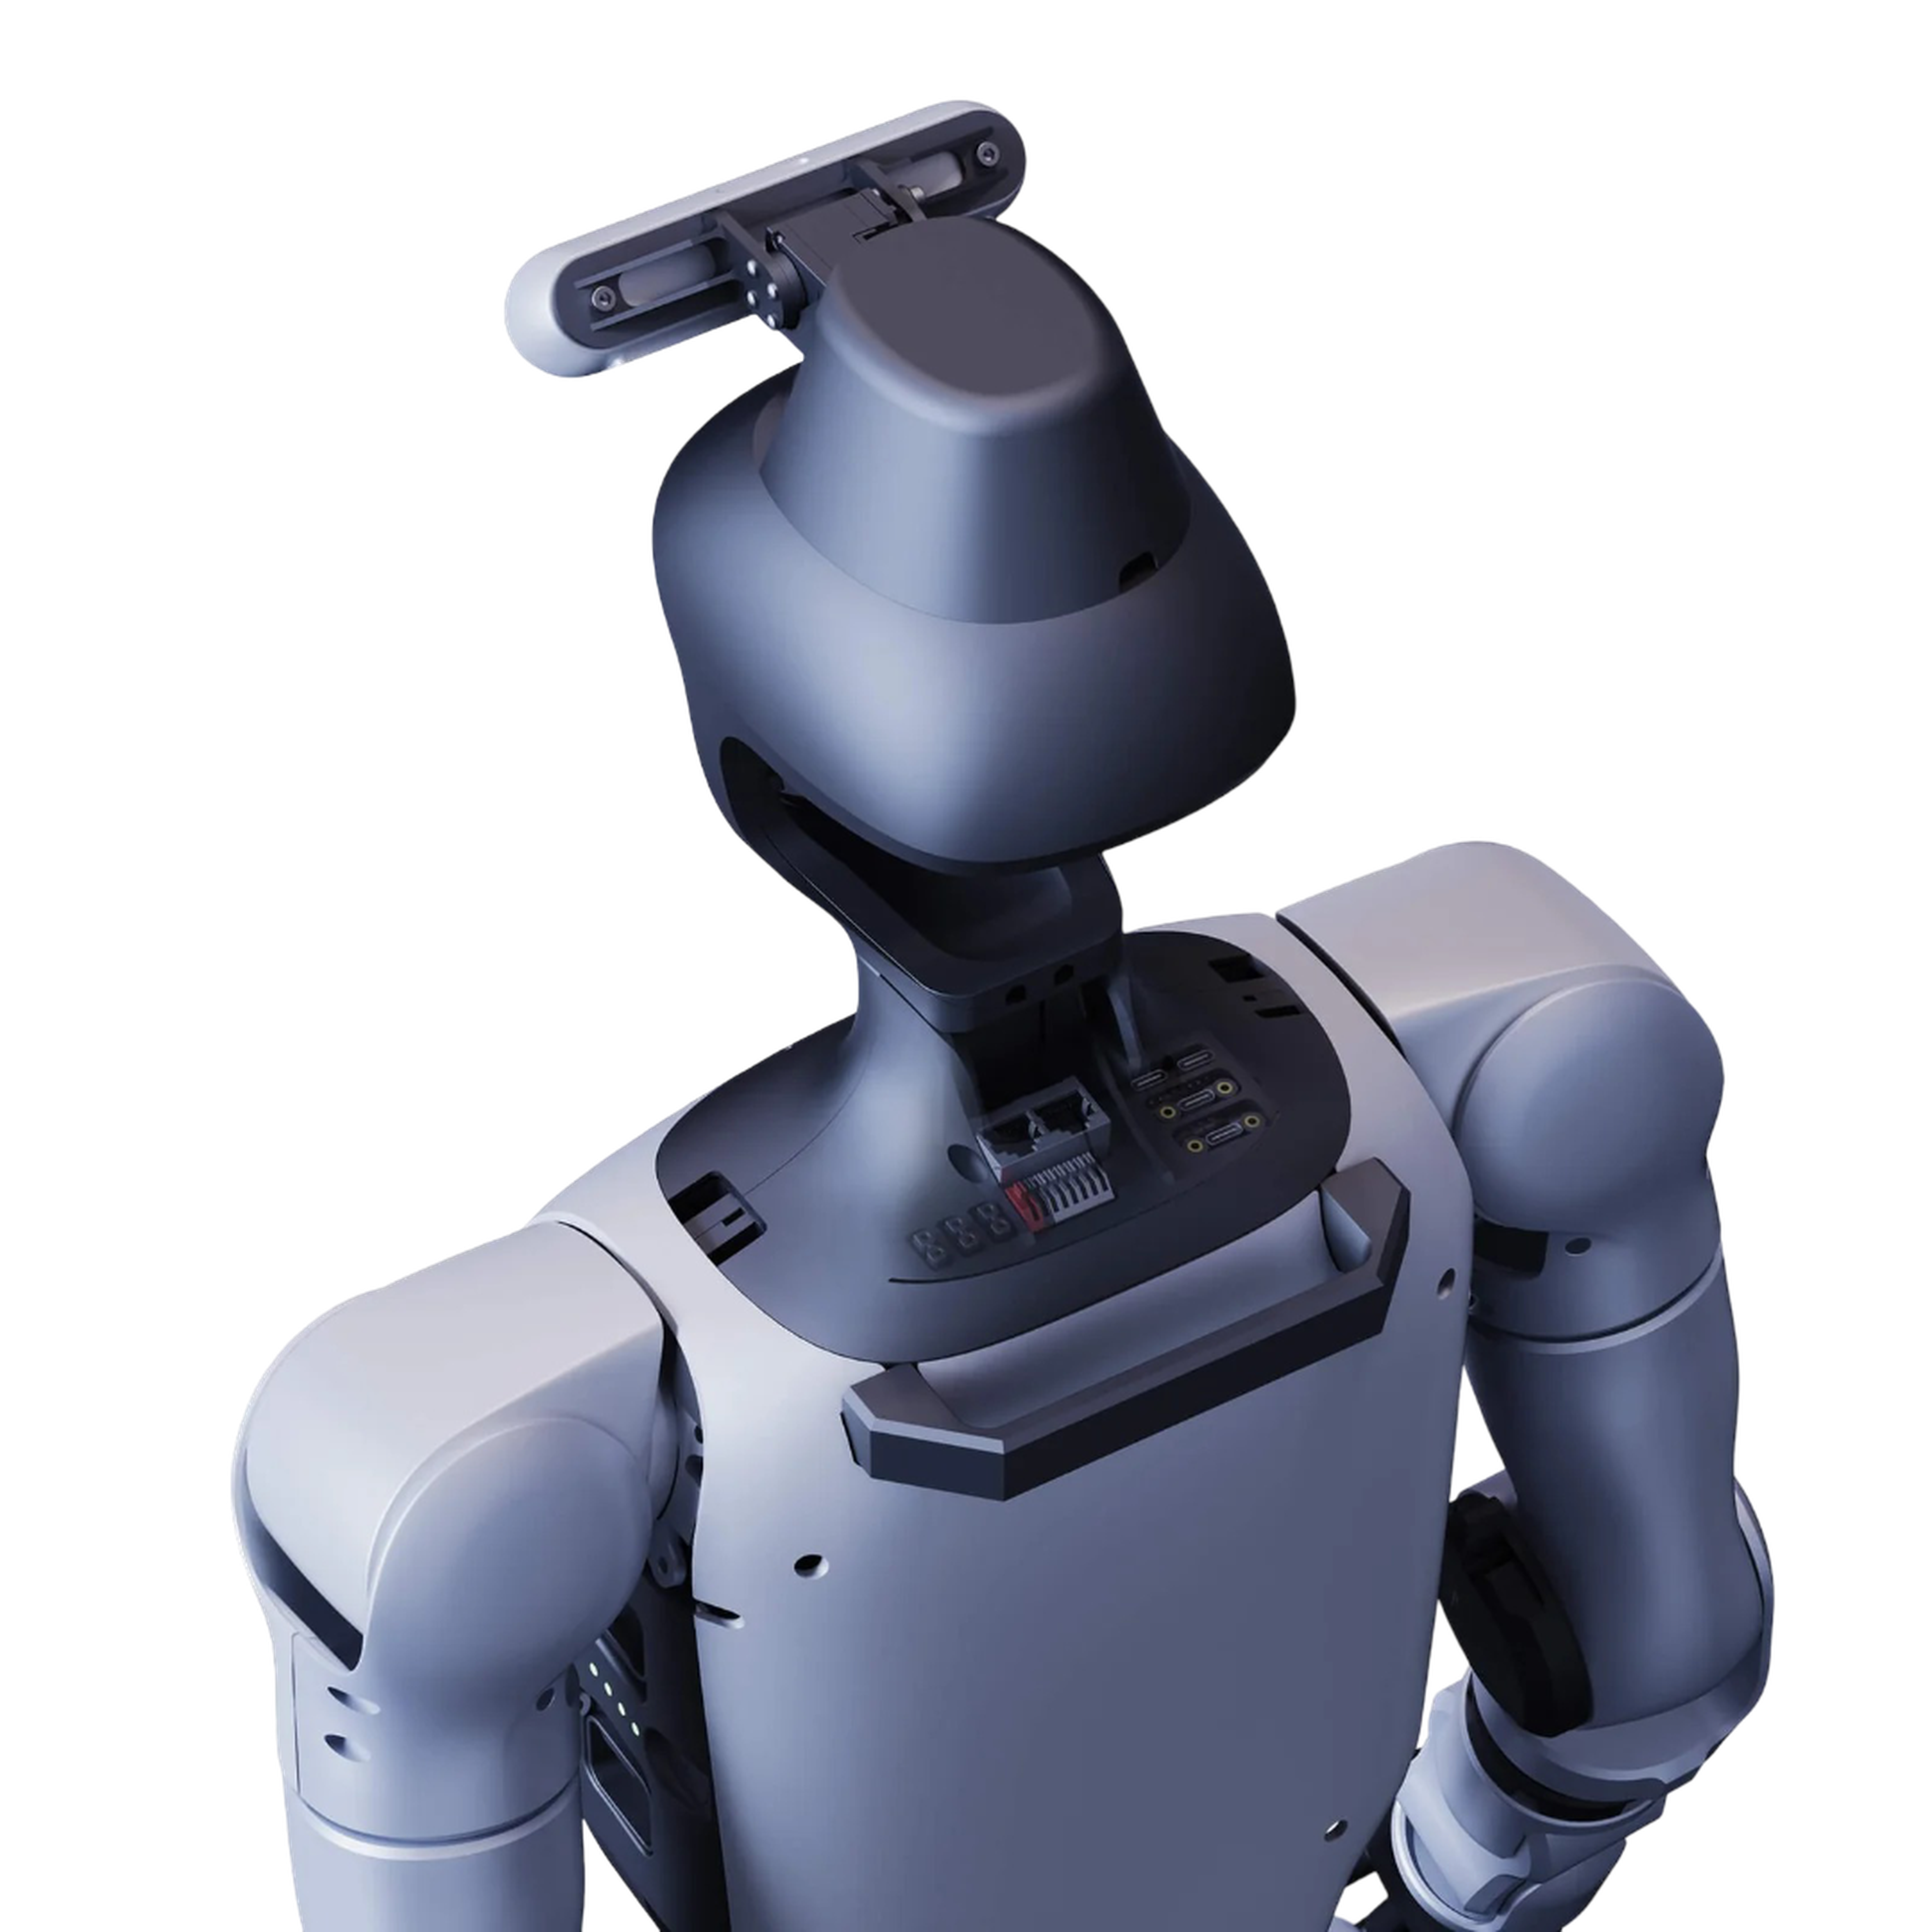
The Unitree G1 Comp features 25 degrees of freedom in the offered configuration. Each leg provides six degrees of freedom, each arm five, complemented by one waist joint and two active head joints. The humanoid stands 1,320 mm tall, with dimensions of 1,320 × 450 × 200 mm when upright. Maximum knee torque is rated at 120 N·m, while the arms support a maximum payload of approximately 3 kg. The two-axis head enables active sensor positioning during dynamic movements. With its 25-DOF configuration, the G1 Comp provides the mobility required for humanoid locomotion, robot soccer, and the development of custom motion control strategies.
100 TOPS and RoboCup SDK for Autonomous Robotics
For AI and perception tasks, the Unitree G1 Comp is equipped with an NVIDIA Jetson Orin NX development computing unit delivering 100 TOPS. Unitree combines this computing platform with YOLO11 and a dedicated RoboCup SDK designed for competition-oriented robotics applications. The Visual Recognition API provides computer vision capabilities, while the Spatial Positioning API supports monocular geometric positioning and binocular depth-based positioning. Through the Motion Control API, perception and positioning data can be incorporated directly into the robot's motion control. The platform also features 3D LiDAR and a depth camera. This allows developers to combine perception, positioning, and motion control on a single robotic platform.
Reinforcement Learning and Sim2Real
The Unitree G1 Comp supports the development of custom motion strategies using reinforcement learning. Unitree provides the unitree_rl_gym framework and supports both Isaac Gym and MuJoCo as simulation environments. The documented development workflow covers the entire process from training in simulation and Sim2Sim validation to Sim2Real deployment on the physical robot. High-level and low-level operation control interfaces, as well as a Status Service, are available for robot control. DDS communication and ROS compatibility enable integration into established robotics software environments. Configurable environments, random seeds, and training iterations support reproducible training and development workflows for humanoid locomotion and competition robotics.
Soluzioni low cost realizzate con RBTX®
Prenota una videochiamata gratuita con un nostro esperto